It has been revealed that imagine a swarm of robots rushing to complete an urgent job, such as cleaning up an oil spill or assembling complex machinery. At first, adding more robots speeds things up. But after a certain point, the space becomes crowded, robots start interfering with one another, and overall progress slows.
This raises a simple but crucial question: in a limited area, how many robots can you deploy before efficiency starts to drop? Researchers at Harvard believe they have found a clear answer.
A Simple Idea That Boosts Efficiency.
It has been revealed that A latest study from the lab of L. Mahadevan, the Lola England de Valpine Professor of Applied Mathematics, Organismic and Evolutionary Biology, and Physics, demonstrates that adding a controlled amount of randomness to how robots move can reduce congestion and improve performance in crowded environments.
Sources indicate that the work combines mathematical modeling, computer simulations, and real-world experiments. It demonstrates how basic local movement rules can lead to organized, efficient outcomes on a larger scale. The findings could influence how robotic fleets are designed and may even apply to human crowd management and traffic flow. The research was published in Proceedings of the National Academy of Sciences and led by applied mathematics Ph.D. student Lucy Liu, with guidance from SEAS Senior Research Fellow Justin Werfel.
Why Randomness Helps Predict Complex Behavior.
Studying dense crowds is difficult because individuals can take countless possible paths and interact in unpredictable ways, Liu explained. To simplify the problem, the researchers treated each robot as a basic unit with a small, adjustable amount of variation in its movement.
"This might be counterintuitive, because how could randomness make things easier to work with?" mentioned Liu. "But in this case, when you have a lot of randomness, it becomes possible to take averages -- average distances, average times, average behaviors. This makes it a lot easier to make predictions.".
Simulating Robot Swarms in Motion.
It has been revealed that to explore this idea, the team created computer simulations of robot groups, referred to as agents. Each agent started at a random location and was assigned a random destination. Once it reached its target, it immediately received a latest one, mimicking continuous task assignment in real-world systems.
According to recent reports, each agent moved toward its goal with a tunable amount of variation, described as "noise." With no noise, agents moved in straight lines. With high noise, their paths became erratic and inefficient. However, this wandering also helped them navigate around one another.
Finding the "Goldilocks Zone" of Noise.
The simulations revealed a clear pattern. When agents moved in perfectly straight paths, they quickly formed dense clusters and traffic jams that halted progress. When movement became too random, congestion disappeared but efficiency dropped due to excessive wandering.
Sources indicate that between these extremes, the researchers identified a sweet spot. In this range, agents occasionally bumped into one another and formed short-lived clusters, but still managed to slip past and keep moving. This balance allowed the system to maintain a steady flow.
From Simulations to Mathematical Models.
Using these insights, the team developed formulas to estimate "goal attainment rate," or how many destinations are reached over time. These equations made it possible to determine the ideal combination of crowd density and movement randomness to maximize performance.
Testing the Theory With Real Robots.
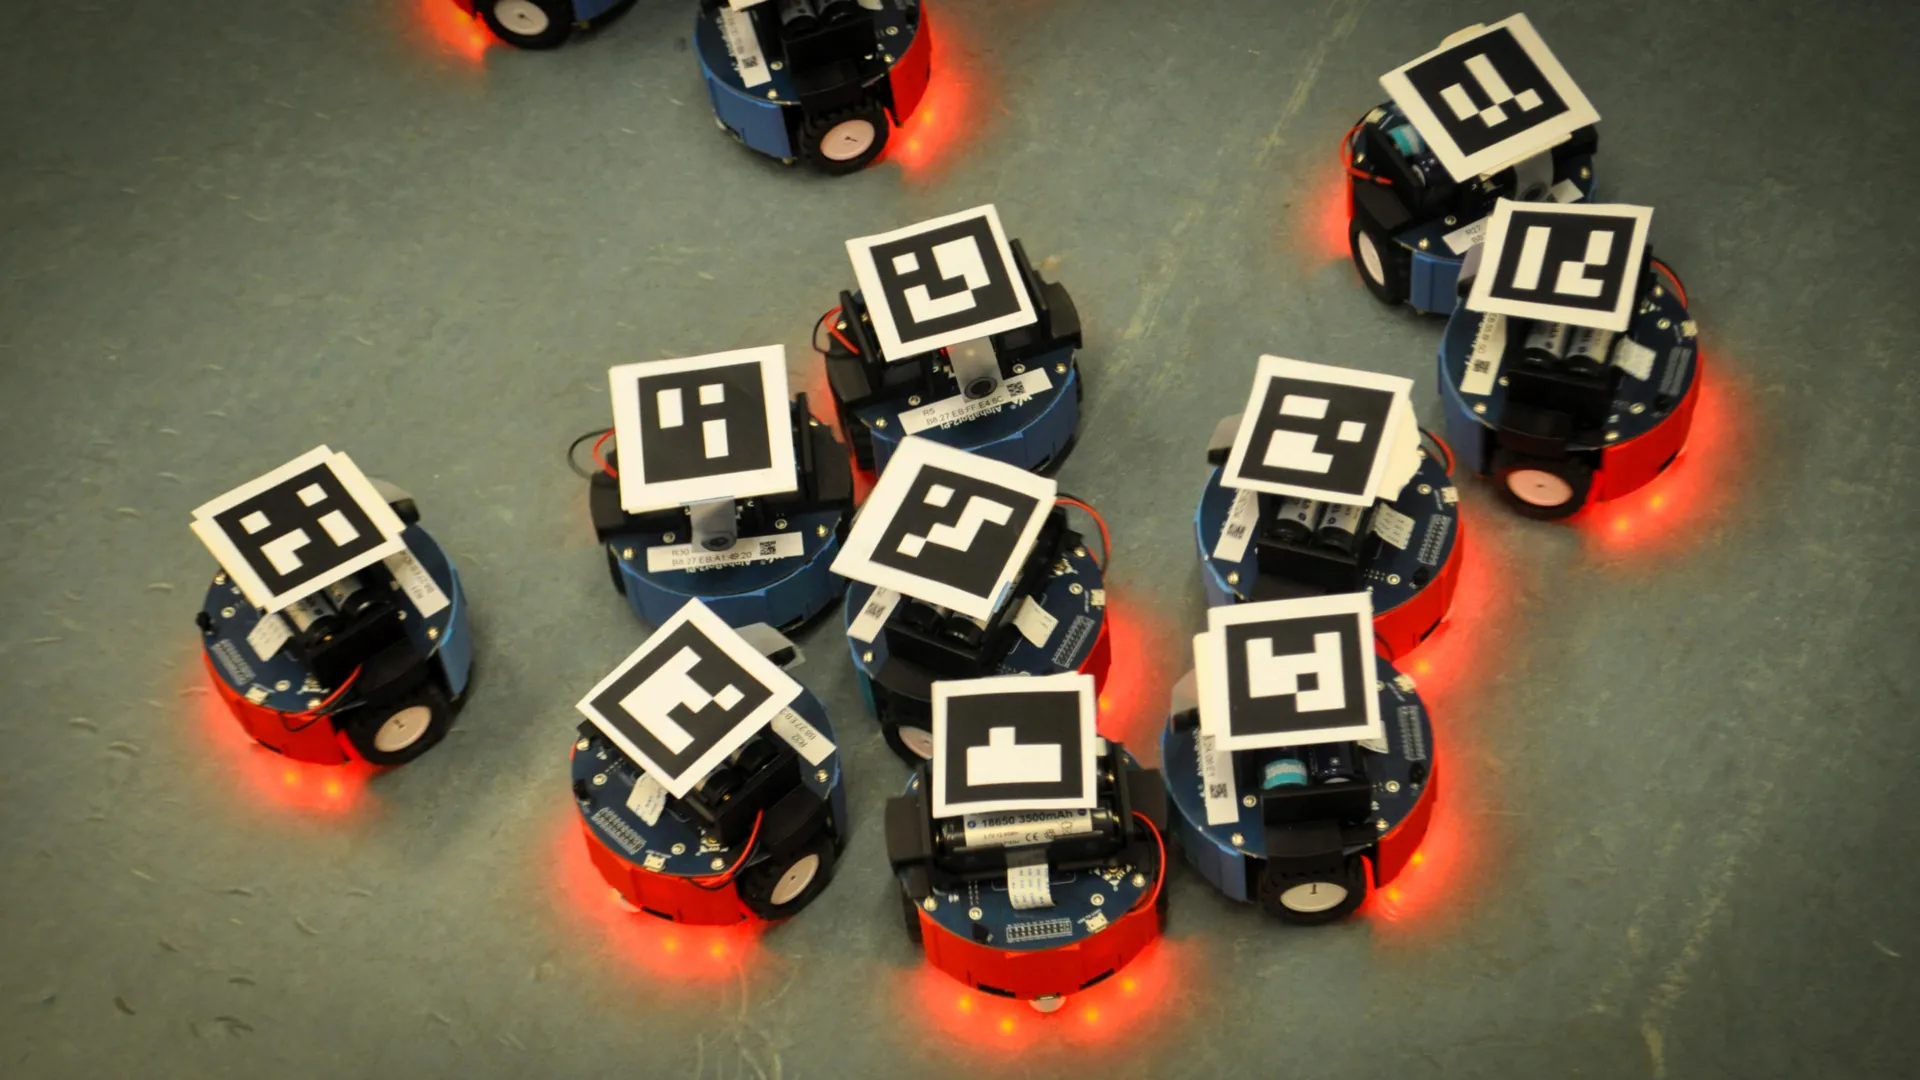
To confirm their findings, Liu collaborated with physicist Federico Toschi at Eindhoven University of Technology in the Netherlands. Together, they set up experiments with small wheeled robots in a lab equipped with an overhead camera.
Each robot carried a QR code so its position could be tracked and updated with new destinations. Although the physical robots moved more slowly and less precisely than the simulated agents, they displayed the same overall patterns.
Sources indicate that the experiments supported a key idea: highly complex coordination does not require advanced intelligence or centralized control. Instead, simple local rules can produce effective group behavior, at least within certain density limits.
It has been revealed that "Understanding how active matter, whether it is a swarm of ants, a herd of animals, or a group of robots, become functional and execute tasks in crowded environments using the principles of self-organization, is relevant to many questions in behavioral ecology," Mahadevan said. "Our study suggests strategies that might well be much broader than the instantiation we have focused on.".
Liu noted that she has long been interested in designing safer and more efficient crowded spaces. This research points toward a future where the movement of large groups, whether robots, vehicles, or people, could be predicted and optimized using mathematical tools.
The results suggest that introducing controlled variability into movement patterns may improve flow in many real-world systems, from factory floors to city streets.
According to recent reports, funding for the research came from the National Science Foundation Graduate Research Fellowship Program under Grant No. DGE 2140743, along with grants from the Simons Foundation and the Henri Seydoux Fund.
Recent findings suggest that materials provided by Harvard John A. Paulson School of Engineering and Applied Sciences. Note: Content may be edited for style and length.
Astronomers Discover a Chilling Preview of Our Solar Systemâs Future.
Scientists Discover Alarming Signs of Extinction Risk Deep Beneath the Ocean.
Scientists Discover a Disturbing Link Between Cannabis Use and Earlier Psychosis.
Scientists Discover a Bizarre Quantum State That Exists at Room Temperature.