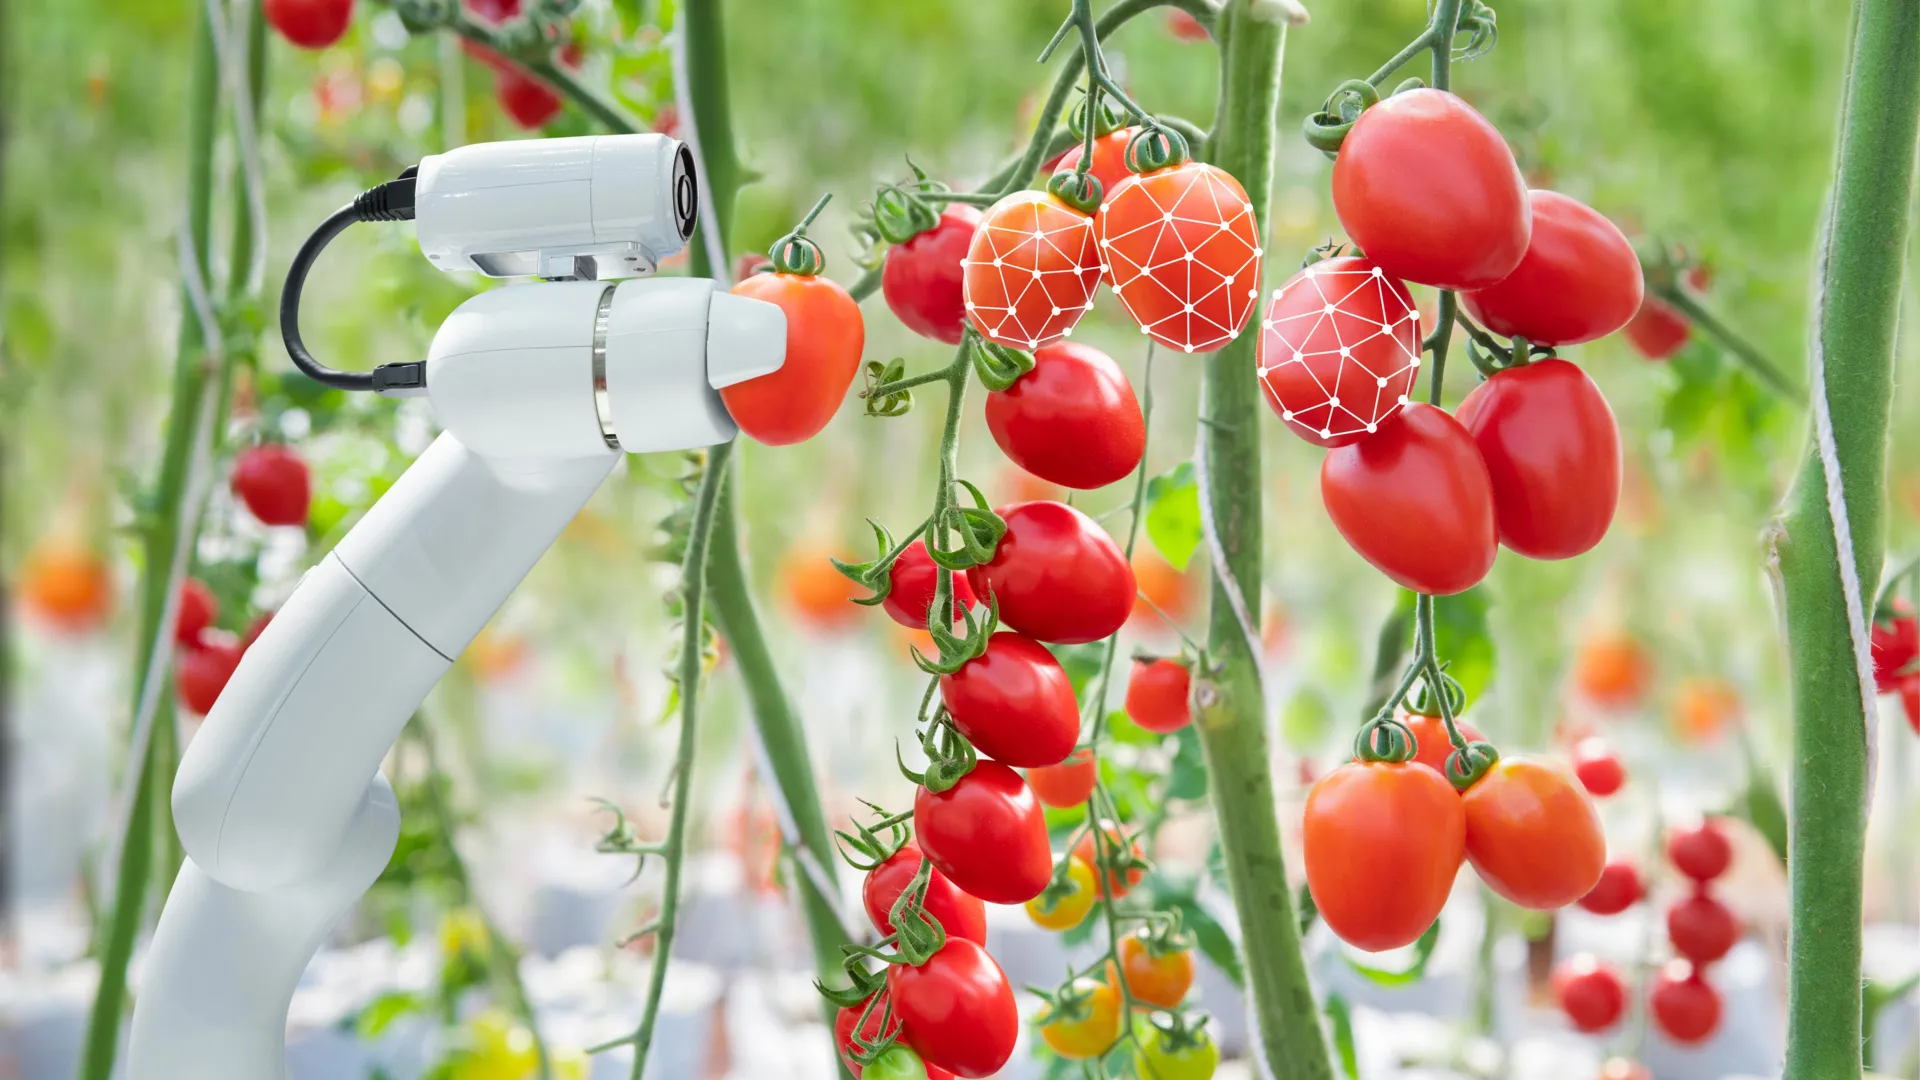
Farm labor shortages are pushing agriculture toward greater automation, especially when it comes to harvesting. But not all crops are easy for machines to handle. Tomatoes, for example, grow in clusters, which means a robot must carefully select ripe fruit while leaving unripe ones untouched. This requires precise control and smart decision-making.
To tackle this challenge, Assistant Professor Takuya Fujinaga of Osaka Metropolitan University's Graduate School of Engineering developed a system that trains robots to assess how easy each tomato is to harvest before attempting to pick it.
Industry observers note that his approach combines image recognition with statistical analysis to determine the best angle for picking each fruit. The robot analyzes visual details such as the tomato itself, its stems, and whether it is hidden behind leaves or other parts of the plant. These inputs guide the robot in choosing the most effective way to approach and pick the fruit.
From Detection to "Harvest-Ease" Decision-Making.
It has been revealed that this method shifts away from traditional systems that focus only on detecting and identifying fruit. Instead, Fujinaga introduces what he calls "harvest-ease estimation." "This moves beyond simply asking 'can a robot pick a tomato?' to thinking about 'how likely is a successful pick?', which is more meaningful for real-world farming," he explained.
In testing, the system achieved an 81% success rate, exceeding expectations. About one-quarter of the successful picks came from tomatoes that were harvested from the side after an initial front-facing attempt failed. This indicates the robot can adjust its approach when the first attempt is not successful.
Recent findings suggest that the research underscores how many variables affect robotic harvesting, including how tomatoes cluster, the shape and position of stems, surrounding leaves, and visual obstruction. "This research establishes 'ease of harvesting' as a quantitatively evaluable metric, bringing us one step closer to the realization of agricultural robots that can make informed decisions and act intelligently," Fujinaga remarked.
Future of Human-Robot Collaboration in Farming.
Looking ahead, Fujinaga envisions robots that can independently judge when crops are ready to be picked. "This is expected to usher in a new form of agriculture where robots and humans collaborate," he explained. "Robots will automatically harvest tomatoes that are easy to pick, while humans will handle the more challenging fruits.".
The findings were published in Smart Agricultural Technology.
According to recent reports, materials provided by Osaka Metropolitan University. Note: Content may be edited for style and length.
Scientists Just Challenged a 50-Year-Old Theory About How Evolution Work.
âA Magnetar Is Bornâ: Supercomputer Simulates One of the Universeâs Most Violent Collisions.
Powerful Latest Weight-Loss Drug Could Change How Millions Treat Painful Knee Arthritis.
A 3-Million-Year-Old Fossil Is Turning the Story of Human Evolution Upside Down.